|
Santosh Rajkumar I am a PhD candidate in Mechanical Engineering at The Ohio State University, working at the intersection of control theory, robotics, and machine learning. I am advised by Dr. Stephanie Stockar. Previously, I was advised by Dr. Debdipta Goswami. Email / CV / Bio / Scholar / Linkedin / Github
Santosh Rajkumar is a PhD candidate in
Mechanical Engineering at
The Ohio State University.
He received his MS in Mechanical Engineering from
Miami University in 2023 with full financial support.
Prior to his graduate studies, he worked as a Senior Engineer at
Indian Oil Corporation Limited,
a Fortune 150 energy company in India.
He earned his Bachelor's degree in Electrical Engineering from
National Institute of Technology Silchar, India, in 2017.
Earlier, he ranked 19th in the Indian state of Assam in the High School Leaving Examination,
among approximately a quarter million candidates.
|
|
News
|
ResearchPhysical AI: Data-efficient, physics-structured world models; learning and state estimation under partial observation; uncertainty-aware robot planning. Robotics and Control: Real-time model predictive control, robot learning, safety-critical control, Koopman representations, geometry-aware modeling, GPU-accelerated optimization, and low-latency solvers for robotic systems. |
|
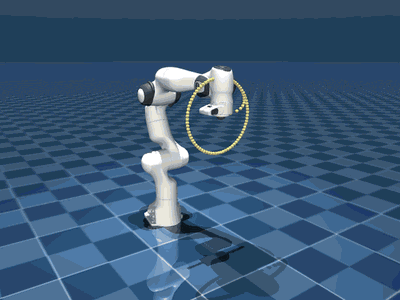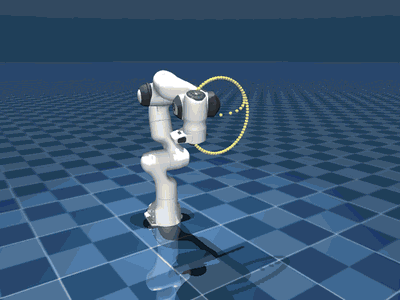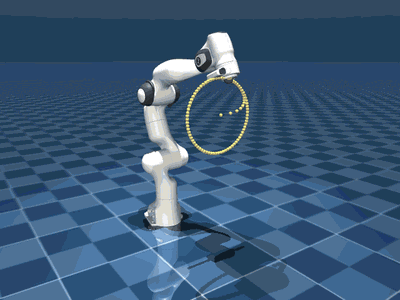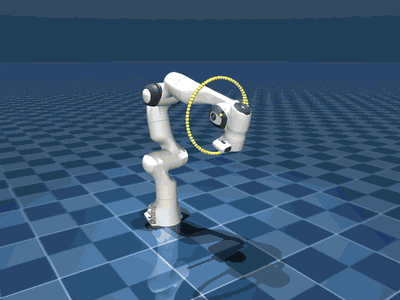
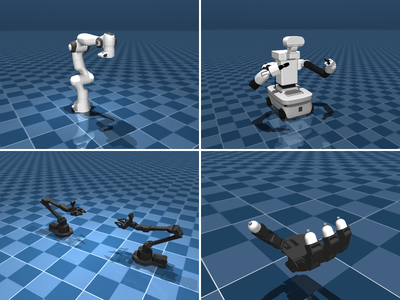
K-PWM: Control-Oriented Structured Bilinear World Models under Partial
Observation
Santosh M. Rajkumar, Sriram Narayanan, Samuel E. Otto, Debdipta Goswami Advances in Neural Information Processing Systems (NeurIPS), 2026 Code* Preprint Cite
@misc{rajkumar2026kpwm,
  title={K-PWM: Control-Oriented Structured Bilinear World Models under Partial Observation},
  author={Rajkumar, Santosh Mohan and Narayanan, Sriram and Otto, Samuel E. and Goswami, Debdipta},
  year={2026},
  eprint={2611.11521},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2611.11521}
}
Probabilistic world model coupling Koopman-bilinear latent dynamics with a nonlinear decoder and model-induced inference, without a separately trained inference network. Trained by GECM with closed-form updates and a Koopman-consistent initialization that selects the latent dimension from data; integrated with uncertainty-aware MPPI control on MuJoCo systems and robots. * Code will be available very soon. |
|
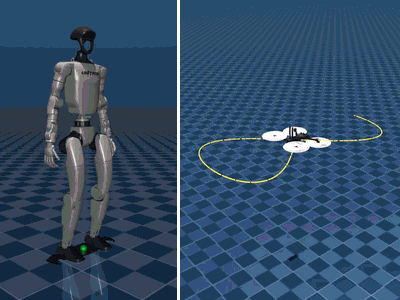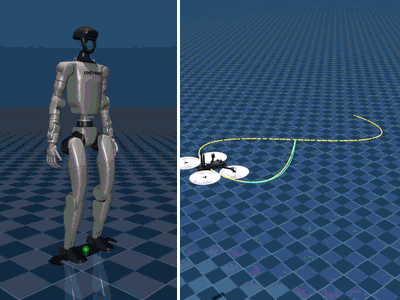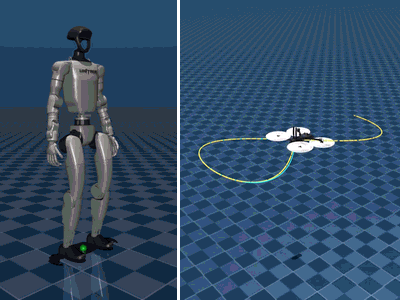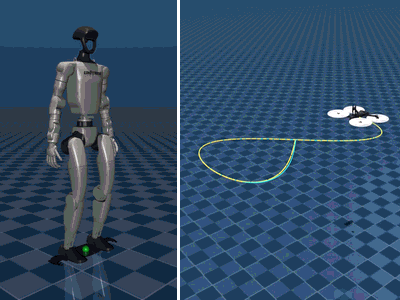
FAME-QP: A GPU-Accelerated Quadratic-Programming Solver for Real-Time Model
Predictive Control
Santosh M. Rajkumar, Debdipta Goswami, Stephanie Stockar Under Review Code* Preprint Cite
@misc{rajkumar2026fameqp,
  title={FAME-QP: A GPU-Accelerated Quadratic-Programming Solver for Real-Time Model Predictive Control},
  author={Rajkumar, Santosh Mohan and Goswami, Debdipta and Stockar, Stephanie},
  year={2026},
  eprint={2611.13766},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2611.13766}
}
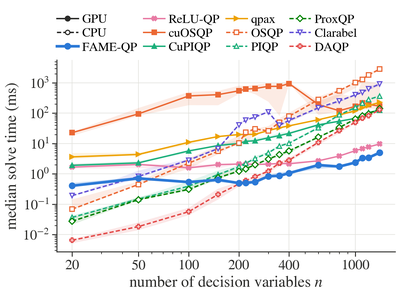
GPU solver for dense quadratic programs in linear MPC, combining constraint-dependent operators with fused kernels replayed through CUDA graphs and lazy operator updates when problem matrices change. Lower latency than competing GPU solvers at matched accuracy, demonstrated on humanoid and quadrotor control. * Code to be released very soon. |
|
Real-Time Linear MPC for Quadrotors on SE (3): An Analytical Koopman-Based
Realization
Santosh M. Rajkumar Chengyu Yang, Yuliang Gu, Sheng Cheng, Naira Hovakimyan, Debdipta Goswami IEEE Robotics and Autmoation Letters (RA-L), 2025 Code Preprint Cite
@article{rajkumar2025real,
  title={Real-Time Linear MPC for Quadrotors on SE (3): An Analytical Koopman-Based Realization},
  author={Rajkumar, Santosh Mohan and Yang, Chengyu and Gu, Yuliang and Cheng, Sheng and Hovakimyan, Naira and Goswami, Debdipta},
  journal={IEEE Robotics and Automation Letters},
  volume={10},
  number={12},
  pages={13018--13025},
  year={2025},
  publisher={Institute of Electrical and Electronics Engineers Inc.}
}
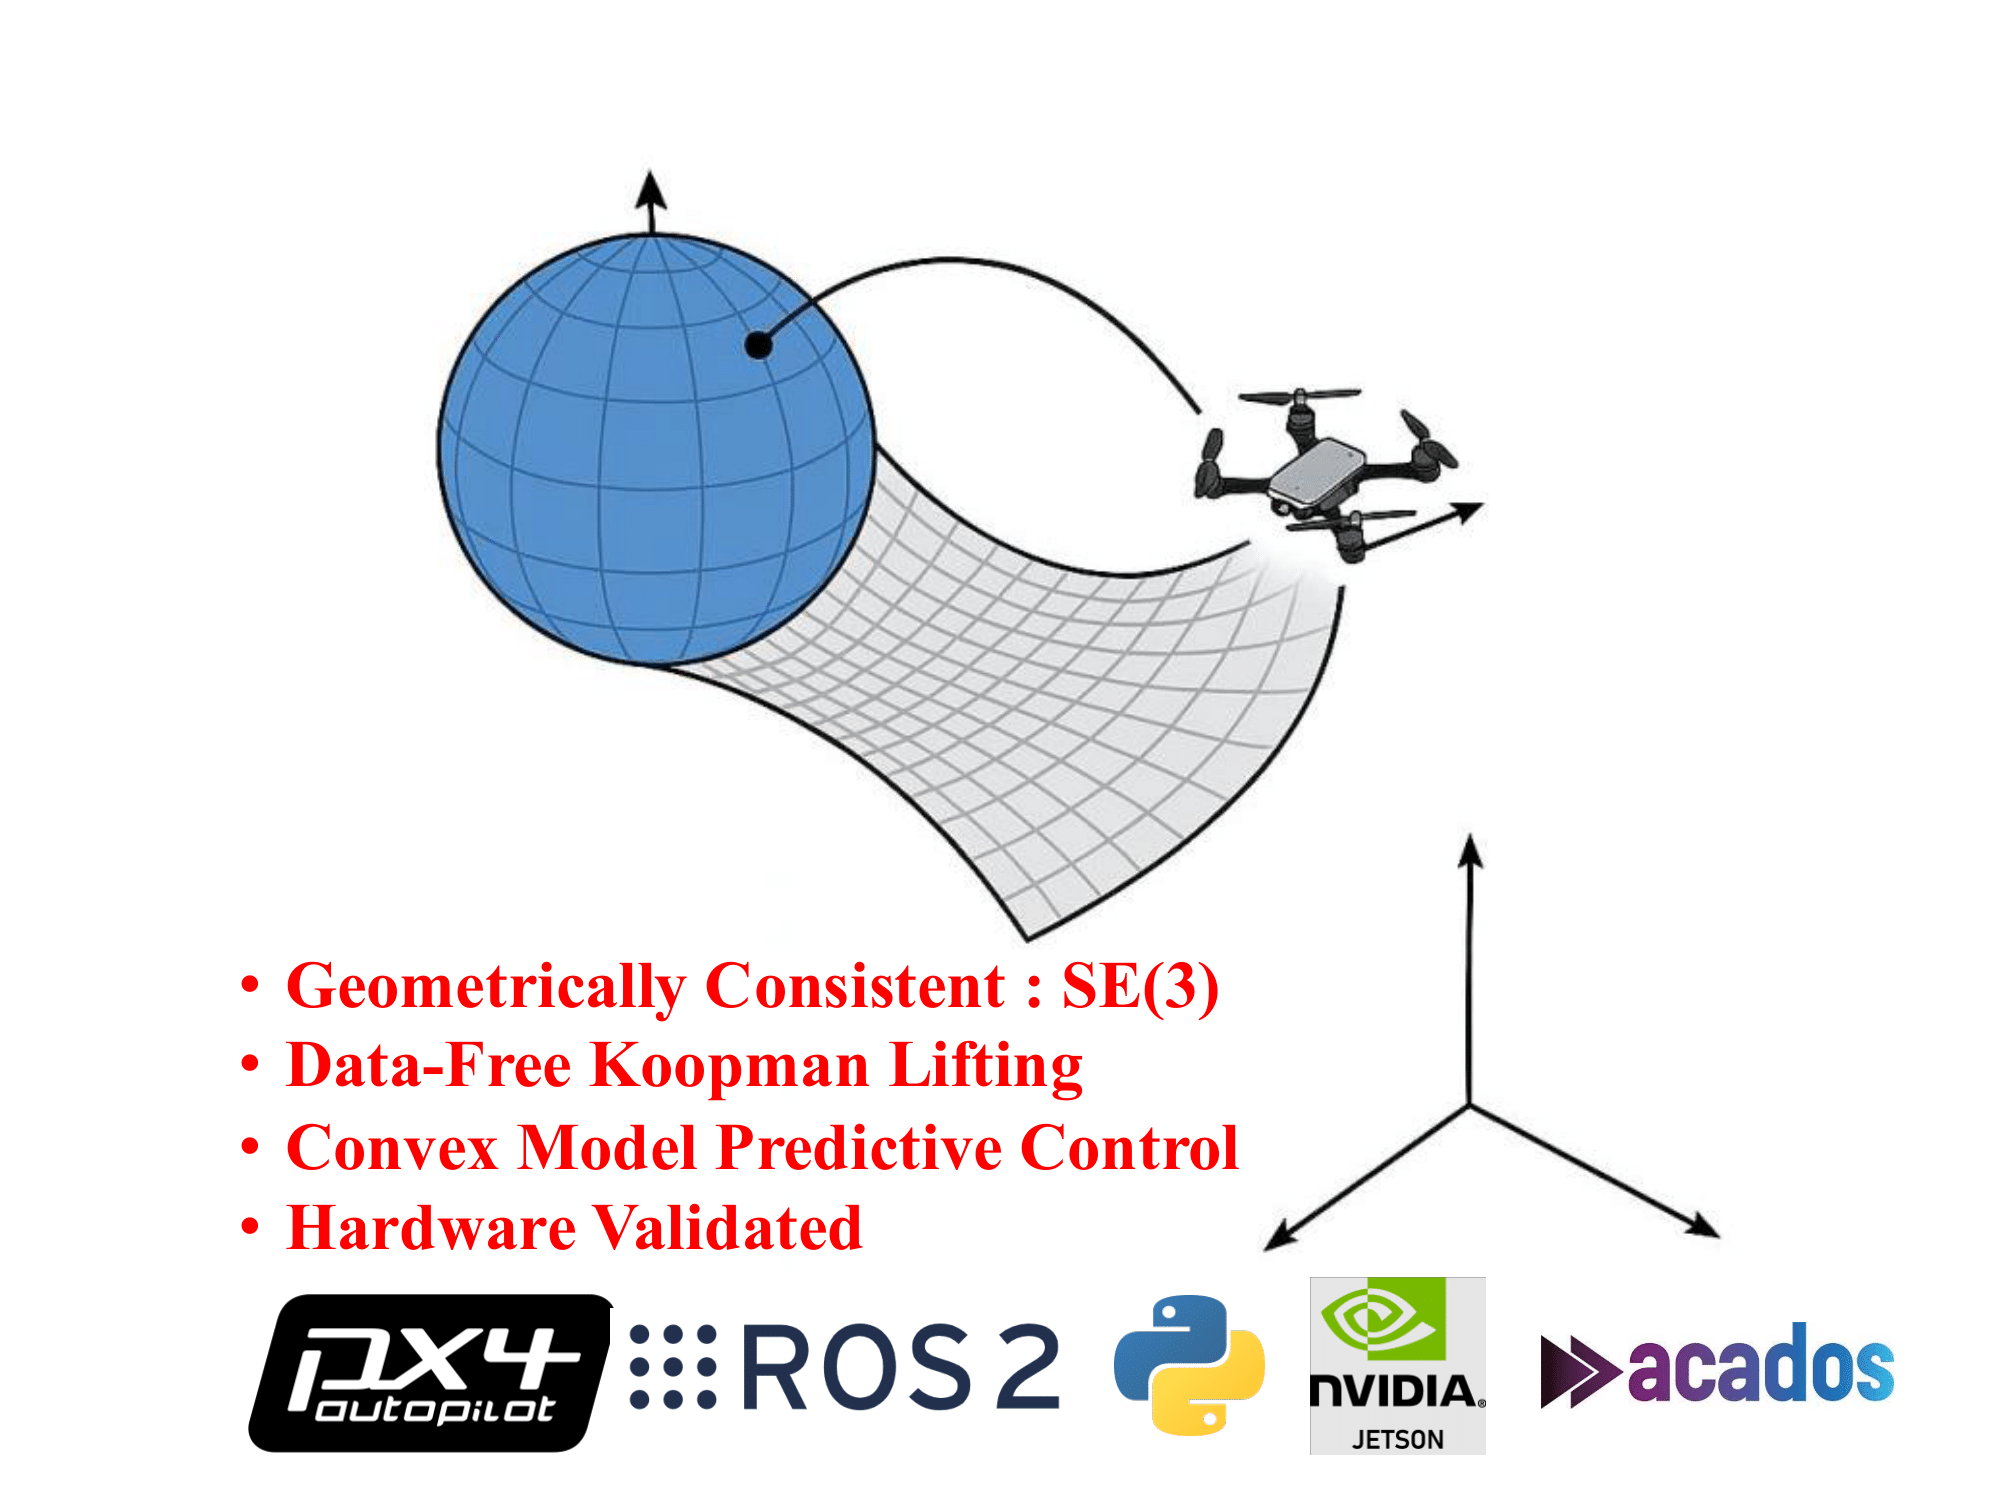
Data-free Koopman linearization of quadrotor dynamics on SE(3) with geometrically consistent lifting. Enables a convex Koopman-based MPC scheme (KQ-LMPC) with 50–70% lower computational cost than NMPC while maintaining comparable tracking performance. First experimental validation of Koopman MPC for quadrotors using analytical lifting functions. |
|
On Data-Driven Koopman Representations of Nonlinear Delay Differential
Equations
Santosh M. Rajkumar, Dibyasri Barman, Kumar Vikram Singh, Debdipta Goswami IEEE Conference on Decision and Control (CDC), 2026 Code Preprint Cite
@misc{rajkumar2026datadriven,
  title={On Data-Driven Koopman Representations of Nonlinear Delay Differential Equations},
  author={Rajkumar, Santosh Mohan and Barman, Dibyasri and Singh, Kumar Vikram and Goswami, Debdipta},
  year={2026},
  eprint={2604.03086},
  archivePrefix={arXiv},
  primaryClass={eess.SY},
  url={https://arxiv.org/abs/2604.03086}
}
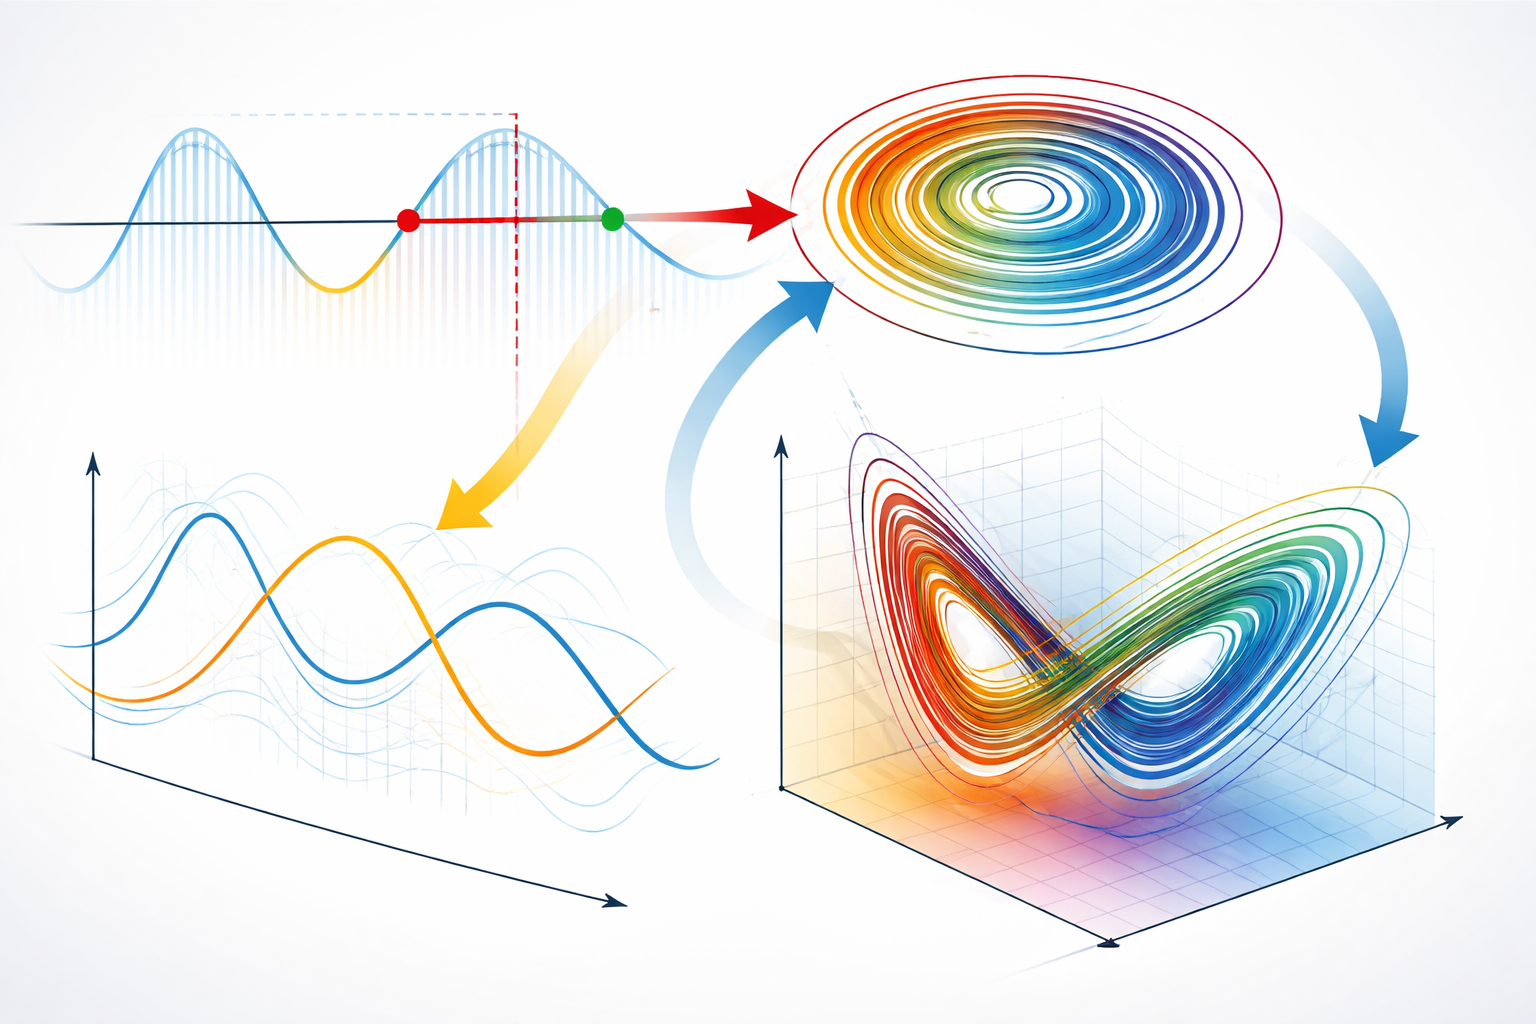
Finite-dimensional Koopman representation of infinite-dimensional nonlinear delay differential equations, built from history discretization and kernel-based extended dynamic mode decomposition (kEDMD). Deterministic error bounds separate the contributions of history discretization, kernel interpolation, and data-driven regression, and a kernel-based reconstruction recovers the discretized states from the lifted Koopman coordinates with provable guarantees. |
|
Geometry-Preserving Analytical Koopman Linearization of Mobile Robots on
SE(2)
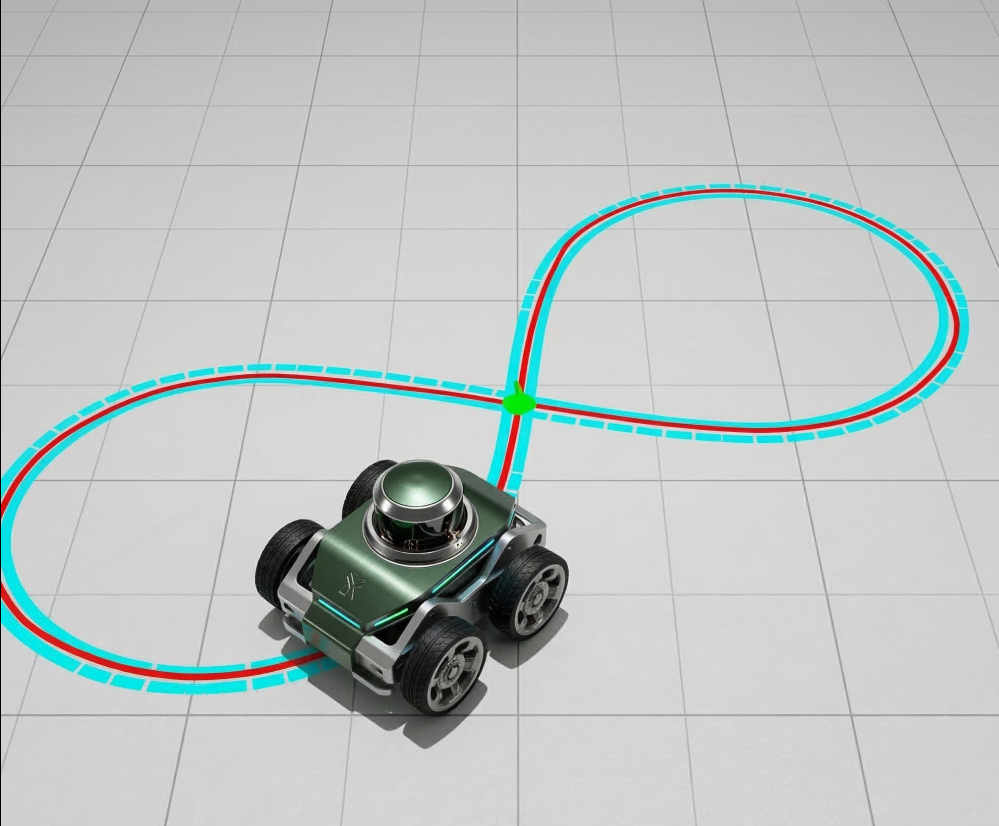
Santosh Sajkumar, Debdipta Goswami Under Review Data-free, geometrically consistent Koopman linearization for wheeled mobile robots with rigorous approximation error bounds and singularity-free LQR tracking control. |
Miscellanea |
|
Miami University
|
Academic Service |
Article Reviewer: ICLR, WACV, IEEE ICRA, IEEE RA-L, IEEE CDC, American Control Conference (ACC), IFAC World Congress, Indian Control Conference. |
Press/Media |
Ohio State MAE News. |
|
Modified from source. |